
openrtm integration plugin for choreonoid, python version manual
✏️ Edit this page on GitHub#contents
The Python version of the Choreonoid OpenRTM integration plugin is a plugin for linking robots on Choreonoid with RTCs developed in Python. The following main functions are available.
Efficient Development of RTCs That Link with Simulators on Choreonoid Using Python
The OpenRTM integration plugin included standard with Choreonoid enables RTC development in C++, but there have been issues in that building the development environment is difficult and compilation takes time, making it inefficient. Therefore, by distributing the prebuilt Choreonoid + OpenRTM integration plugin Python version, you can develop RTCs that link with simulators on Choreonoid immediately after downloading.
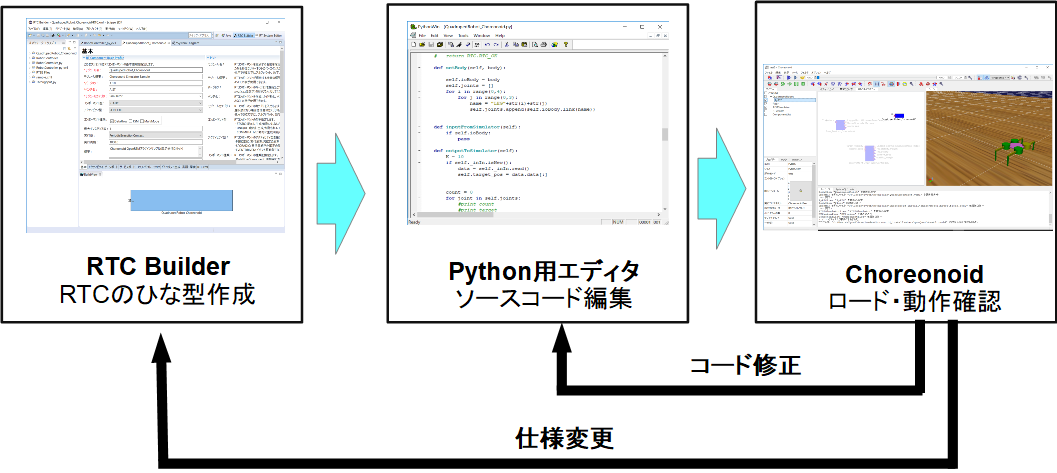
Fast Development with a Dynamic Python Code Editing Tool
This plugin includes a Python editor that runs on Choreonoid.
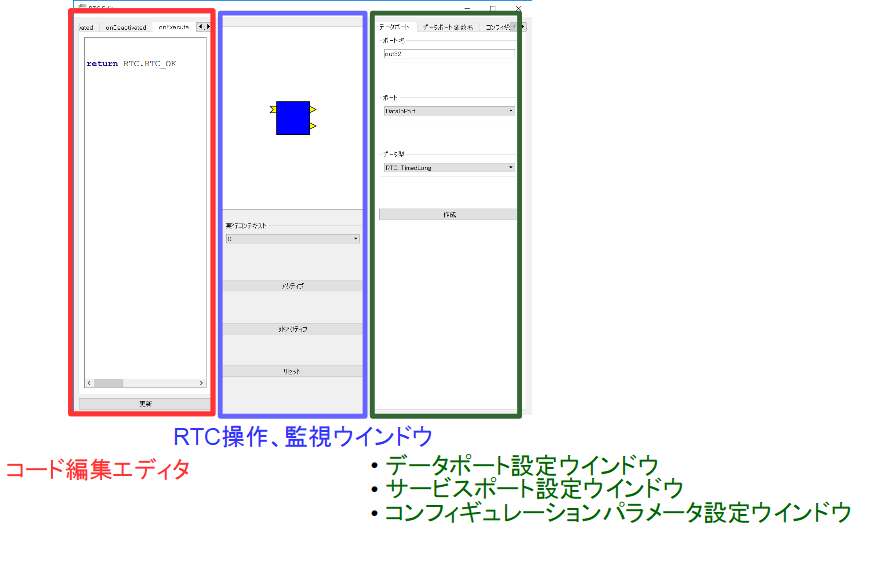
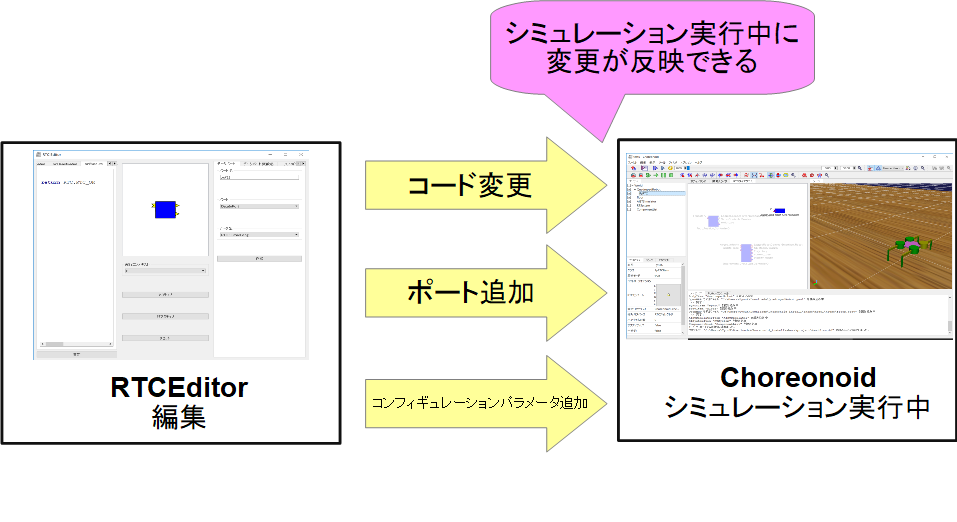
Simply editing and saving code in the Python editor immediately reflects the changes in the RTC. It also supports settings for data ports, service ports, and configuration parameters, enabling RTC development and operation checks using only Choreonoid and Python.
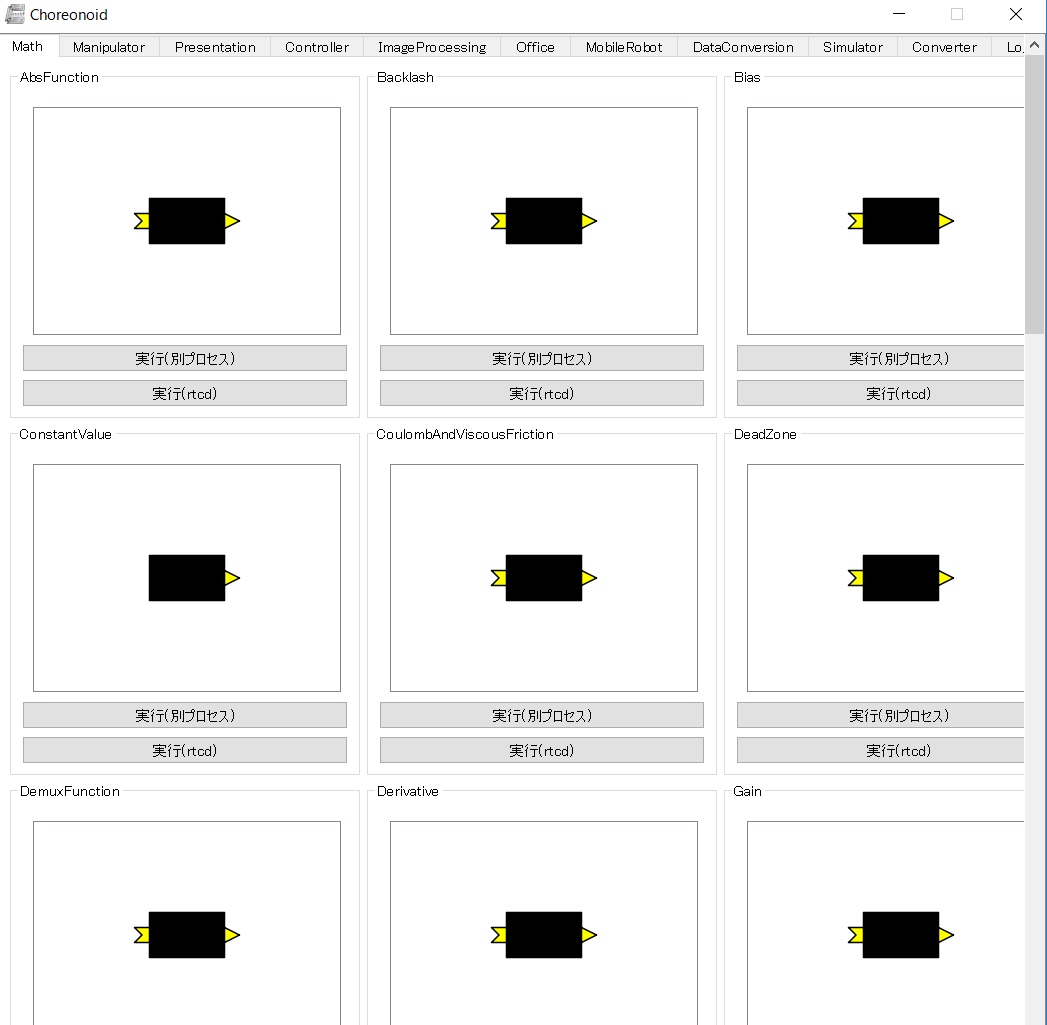
RTC Launcher
A launcher that displays RTCs in a list and can start them with a single button runs on Choreonoid. This plugin includes 73 types of RTCs as sample components, allowing you to develop various RT Systems on Choreonoid.
RTC Registration Procedure
Create a folder with an appropriate name (for example, TestRTC) under share/rtc in the Choreonoid installation directory.
Then place RTC.xml and the Python file, executable file, or dll for running the RTC under it, and registration is complete. The Python file, executable file, and dll can be found by search even if they are not directly under the TestRTC folder.
- When registering a C++ RTC, since this plugin is developed with Visual Studio 2015 (64-bit), dll files cannot be loaded unless they are built with the same Visual Studio. It can be started from an executable file, but in that case, the folder containing the required dll files (RTC120_vc12.dll, etc.) must be added to PATH.
 choreonoid
    |-share
      |-rtc
        |-TestRTC
          |-RTC.xml
            |-TestRTC.py(もしくはTestRTCComp.exe、TestRTC.dll)
Installation Procedure and Tutorials
The installation procedure and tutorials are described on the following pages.
- Installation Procedure for the OpenRTM Integration Plugin for Choreonoid, Python Version
- OpenRTM Integration Plugin for Choreonoid, Python Version Tutorial (TankJoystick)
- OpenRTM Integration Plugin for Choreonoid, Python Version Tutorial (Quadruped Robot)
- Troubleshooting for the OpenRTM Integration Plugin for Choreonoid, Python Version
- OpenRTM Integration Plugin for Choreonoid, Python Version (Notes)